Forge
The robotics data toolkit and data engine.
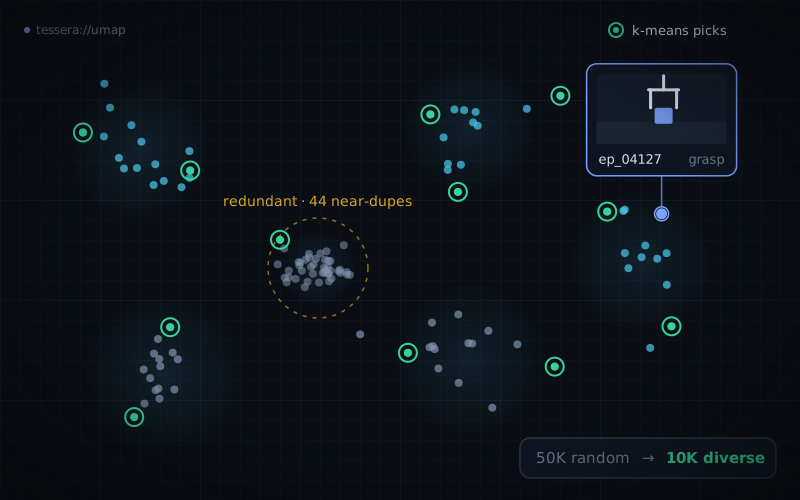
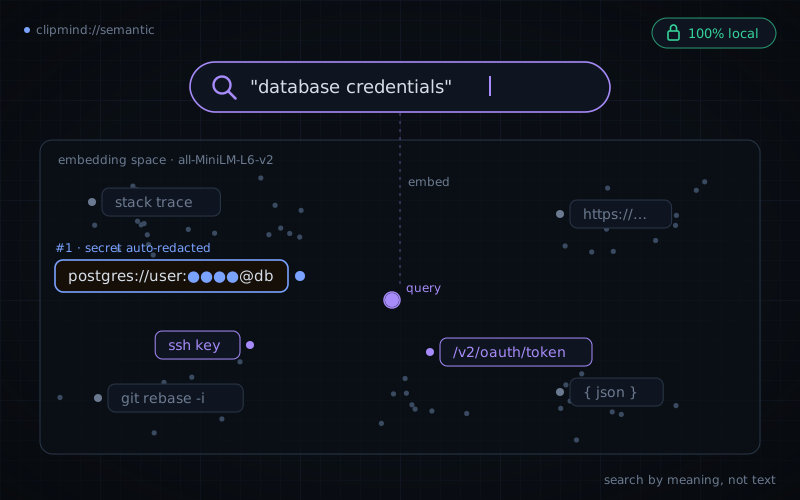
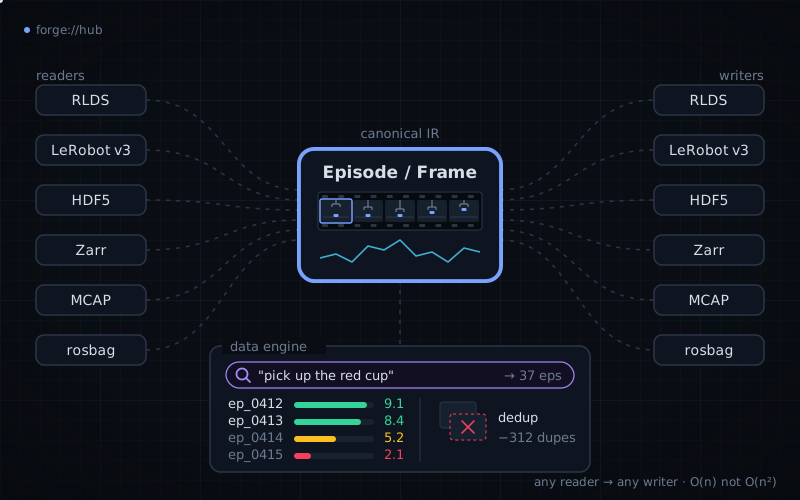
Convert between every major robot-learning format (RLDS, LeRobot v2/v3, HDF5, Zarr, MCAP, rosbag) through a canonical Episode/Frame representation, so adding one reader gives you every writer instead of N×M converters. Score episodes on proprioceptive quality metrics (LDLJ smoothness, dead actions, gripper chatter), then register everything in a DuckDB catalog you can query with SQL, search semantically with SigLIP, and dedupe.
$ pip install forge-robotics
$ forge quality hf://lerobot/pusht